Abstract
Spatial intelligence depends on world representations that capture the geometry of physical space and how it changes over time. Emerging applications in extended reality (XR), artificial intelligence (AI), robotics, and autonomous systems, require efficient processing of dynamic 3D world models (i.e., 4D). Unlike conventional digital media, 4D data structures lack a regular pixel grid such that their geometry, topology, and connectivity can change over time, making compact representation and temporal compression challenging. In this talk, Professor Dasari will present new methods for representing and processing 4D geometry, and the foundational data infrastructure needed to support emerging spatial intelligence applications. He will describe how volume tracking enables temporal prediction for mesh sequences with changing connectivity and how implicit surfaces and learned 4D representations offer complementary approaches to encoding evolving geometry. He will also introduce Open4D, an NSF-supported initiative to build open infrastructure for processing, compressing, and streaming 4D data.
Biography
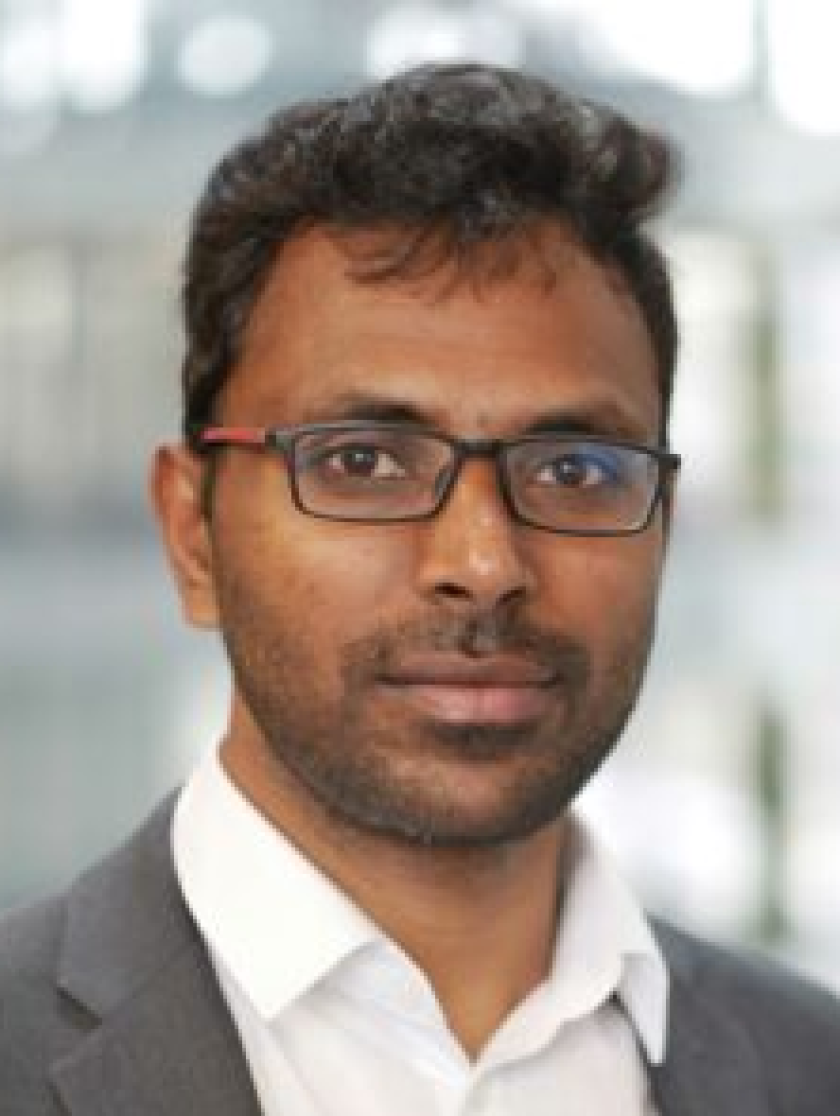
Mallesham Dasari is an assistant professor of electrical and computer engineering at Northeastern University, where he directs the Spatial Intelligence Research Group. His research develops representations, algorithms, and systems that enable machines to perceive, represent, communicate, and interact with the physical world, with applications in XR, AI, robotics, and intelligent wearables. He leads Open4D, an NSF-supported open-source initiative to build shared infrastructure for dynamic 4D data. His work is supported by the NSF, DoD/NSA, and the AI-RAN Alliance. He has received the NSF CAREER award, the AI-RAN Alliance Innovation award, and several best paper and demo awards. He received his doctoral degree in computer science and engineering from Stony Brook University in 2021 and was a postdoctoral researcher at Carnegie Mellon University before joining Northeastern University in 2024.